- This topic is empty.
-
AuthorPosts
-
2026-11-19 at 5:55 pm #13790
Understanding the Demand for Precision Robot Joint Actuators With Magnetic Encoders
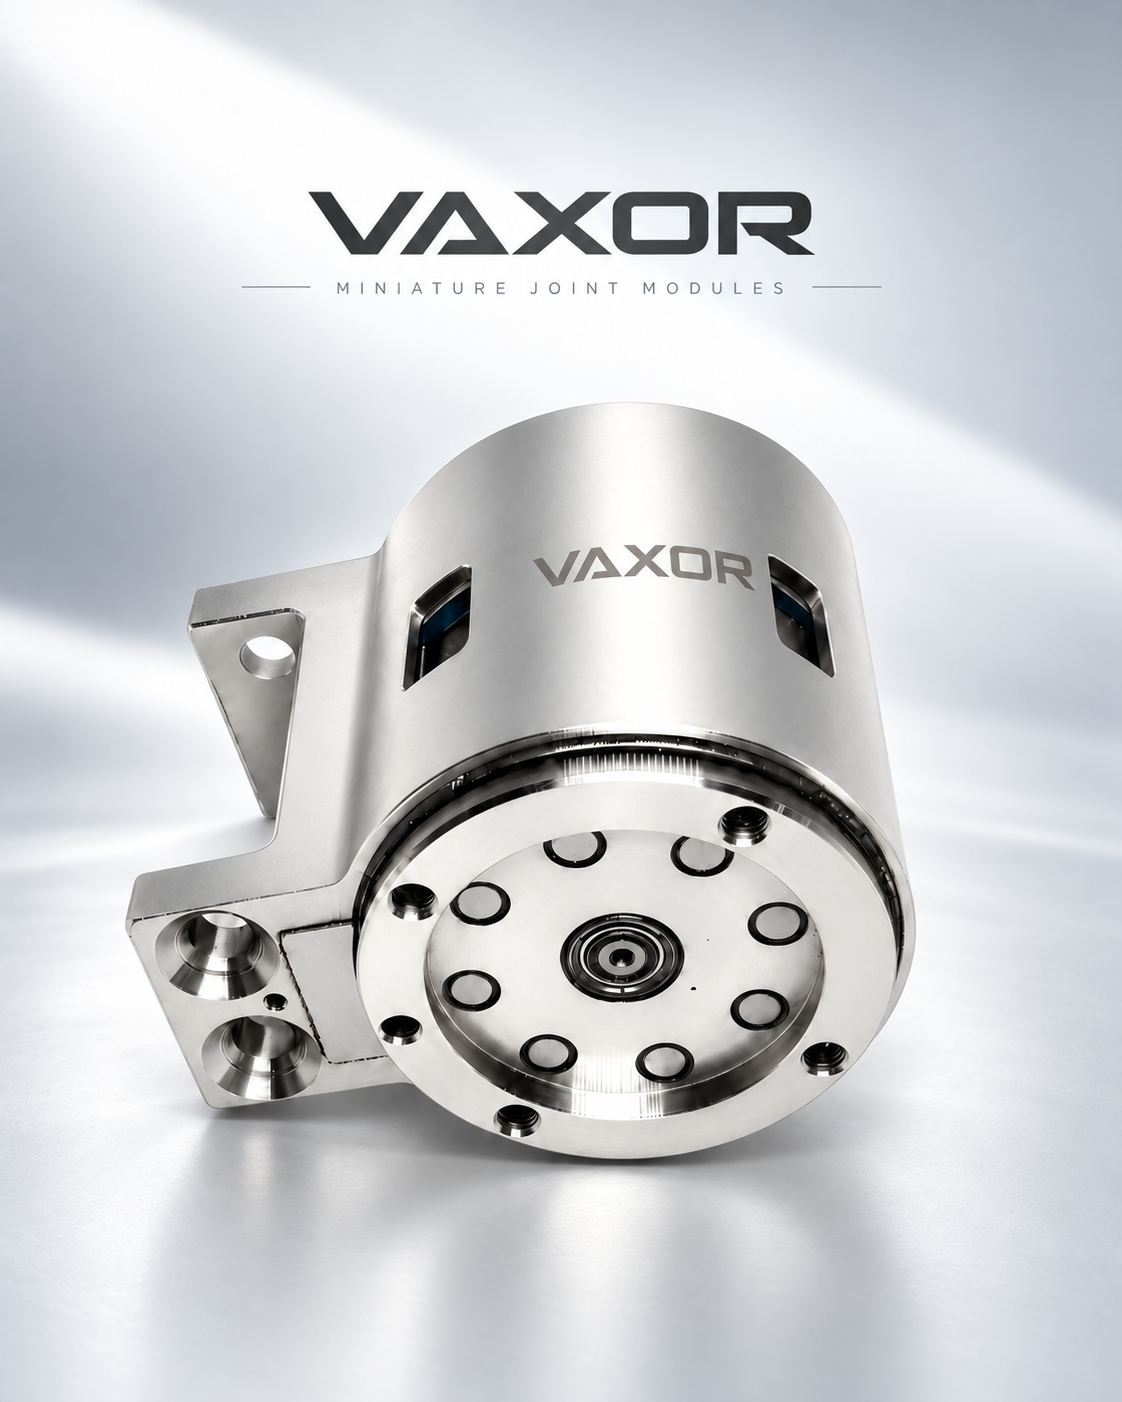
As robotics applications move toward dexterous hands, bionic limbs, and highly integrated industrial systems, engineers increasingly search for a robot joint actuator with a magnetic encoder that can deliver compact form factors without sacrificing torque density or positional accuracy. This combination—axial flux motor technology, cycloidal gear reduction, and non-contact absolute magnetic encoding—addresses a persistent industry pain point: achieving high torque density, precision, and a compact footprint in micro-manipulation and high-load robotic applications. VAXOR-MOTOR, operating under the VAXOR brand, has positioned itself as a provider of integrated micro-actuation solutions built specifically around this intersection of axial flux motors, micro cycloidal gear reducers, and non-contact encoder integration.
Why Axial Flux Motors Paired With Magnetic Encoders Matter
The core value proposition behind VAXOR’s approach is straightforward: high torque density and rigidity are achieved through the integration of axial flux motors and micro cycloidal reducers. On the electromagnetic side, VAXOR’s designs optimize phase imbalance to within 5%, which directly supports higher yield and power density during manufacturing. This matters for buyers because phase imbalance issues in ultra-micro motors typically translate into inconsistent performance and increased production costs—two problems that compact robotic systems cannot absorb when operating at scale.
Layered onto this motor platform is the non-contact absolute magnetic encoder, which provides precise position feedback without the wear issues associated with contact-based sensing. For robotic joints that require repeatable, fine-grained motion control—such as dexterous hand fingers or multi-joint industrial arms—this encoder integration is what allows the actuator to report its exact position reliably over continuous operation cycles.
The Micro Joint Actuator Module Lineup
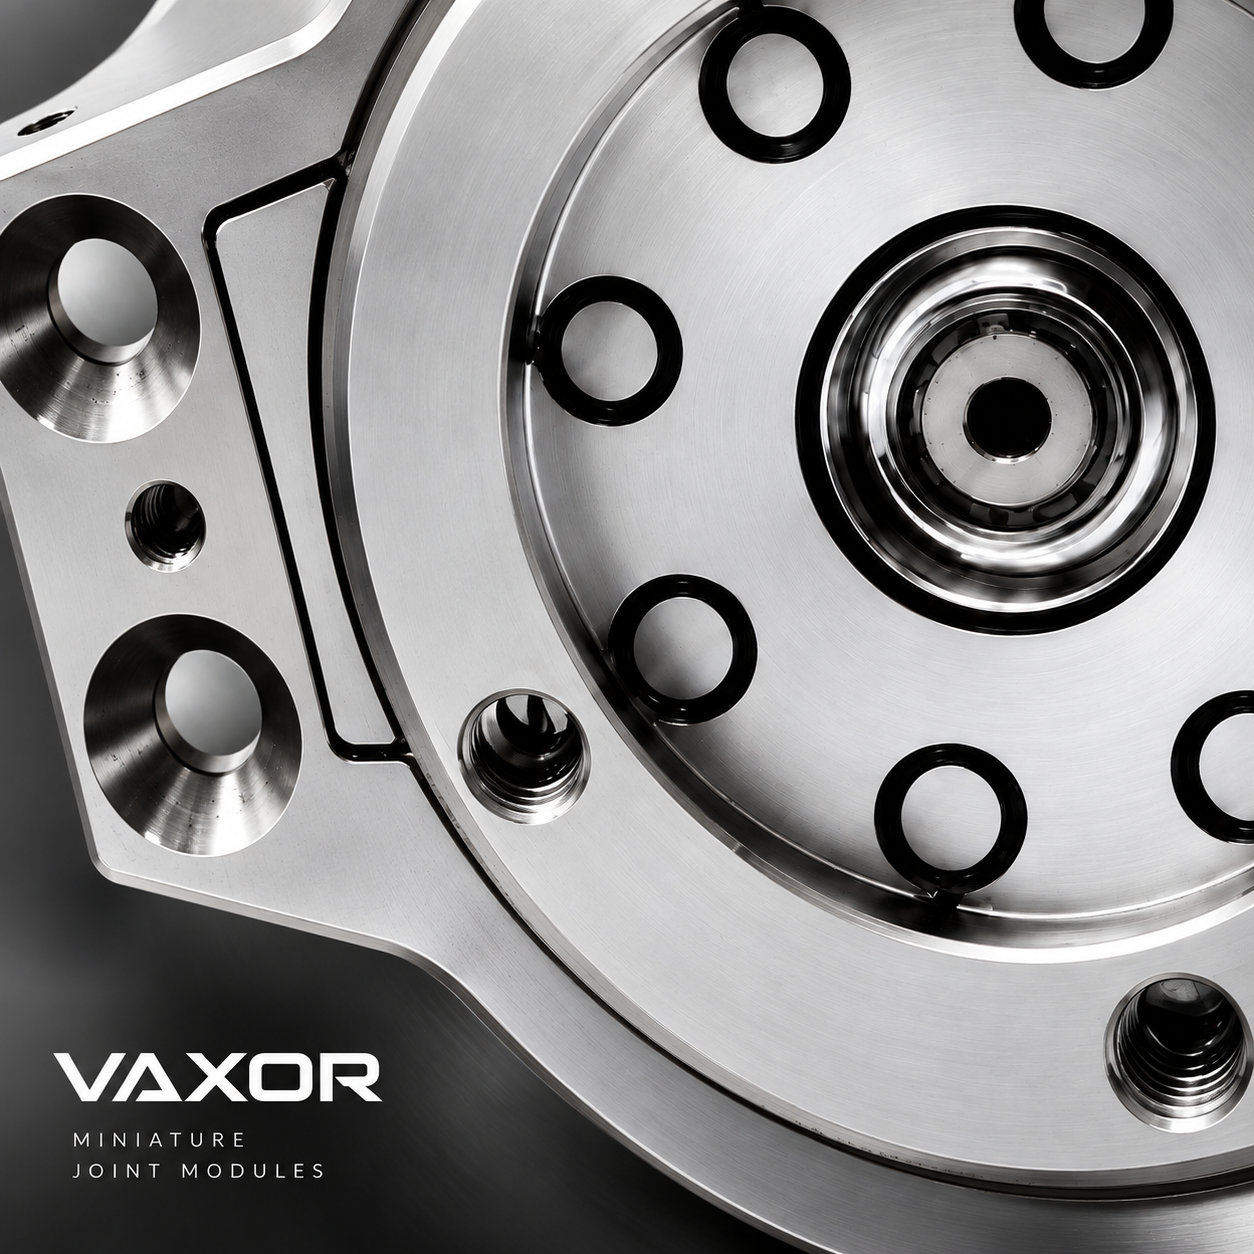
VAXOR’s Micro Joint Actuator Modules product line is built for precision actuation in dexterous robotic hands, highly integrated robots, and general mechanical motion control. The lineup spans four diameter classes, each targeting a different load and application profile.
Φ16mm Micro Joint Module (X16S / X16L)
The Φ16mm module is designed for precision micro-manipulation in highly integrated robotic systems. It is notably lightweight—24.3g for the S-version and 26.1g for the L-version—while still delivering a continuous stalling torque greater than 7.1 mNm and a maximum stalling torque above 16.5 mNm. It integrates gear reduction ratios of 30, 40, and 50, allowing it to provide high torque within a 16mm diameter footprint. The absolute magnetic encoder built into this module enables high-precision motion control, while SPI communication ensures low-latency control response. Thermal management is handled through chassis temperature limits of 80°C, 115°C, or 145°C depending on power loss conditions, which helps prevent overheating during sustained operation.
Φ20mm Micro Joint Module (X20S / X20L)
Stepping up in load capacity, the Φ20mm module targets medium-load precision actuation for bionic and automation applications. It delivers a continuous stalling torque above 17.2 mNm and a maximum stalling torque above 35.3 mNm, while supporting flexible 12V, 24V, and 48V operation. Its multi-ratio gearbox—available in 15, 30, and 50 ratios—balances speed and torque requirements, and at ratio 50 the assembly reaches a stalling torque of up to 450 mNm, suitable for higher-load robotic joints. The standardized FPC 7PIN interface simplifies integration into robotic limbs by consolidating power and data wiring.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ)
For industrial and medical robotics requiring higher output torque, the Φ25mm module uses the CAN FD protocol for robust communication in demanding industrial environments. It achieves a continuous stalling torque of up to 1150 mNm at ratio 50, with reduced backlash of 15 Arcmin for high motion accuracy. Its mechanical strength limits reach 1800 mNm initial torque in a cold state, supporting peak load scenarios.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ)
At the top of the range, the Φ30mm module is built for heavy-duty micro-robotic applications. It delivers a continuous stalling torque of up to 1500 mNm at ratio 50 and reaches gear efficiency of up to 75% at ratio 30. CAN FD integration supports complex network architectures for multi-joint robots, while its total inertia of 30.4 gcm² provides stability during high-load motion.
Ultra-Micro Brushless and Coreless Motors for Related Applications
Beyond the joint modules, VAXOR’s G04P, G05P, and G06P series offer ultra-compact power for precision instruments, addressing the high cost and low yield typically associated with sub-6mm motor production. These motors range from 1.7g to 3.75g in weight with no-load speeds between 55,000 and 63,000 RPM, supporting applications such as micro-pumps and drones. Thermal resistance up to 145°C and terminal resistance as low as 1.6Ω contribute to electrical efficiency, while the same phase imbalance control within 5% applies here, improving yield and reliability. These motors have been applied in medical micro-surgical robots, photonics for precision optical adjustments, and consumer electronics such as miniature haptics and pumps.
Platform Compatibility and Integration
VAXOR’s actuator platform supports 12V, 24V, and 48V DC bus systems, giving integrators flexibility across different robotic and industrial power architectures. Communication is handled through SPI or CAN FD protocols, and the physical interface uses an FPC 7PIN connector with 0.5mm pitch, carrying VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) lines. This openness in protocol and interface design is intended to streamline integration into existing robotic control systems rather than requiring custom wiring solutions.
Documented Applications
Several use cases illustrate how these modules function in practice. Robotic dexterous hands have utilized the X16 and X20 modules to achieve high-integration mechanical motion control, enabling human-like finger dexterity. Industrial automation systems have integrated Φ30mm modules into precision transmission systems, achieving gear efficiency of 75% and reducing mechanical backlash to 15 Arcmin. Micro pump systems have employed G05P ultra-micro motors operating at 55,000 RPM to drive fluid transmission in medical and consumer applications, emphasizing low-cost, high-power-density operation. In photonics, ultra-micro brushless motors have been applied for precision positioning in optical instruments, benefiting from the sub-5% phase imbalance for stable performance.
Business Model and Support
VAXOR follows a product-based pricing approach for its standardized X16, X20, X25, and X30 module series, with deployment supported through standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols. After-sales support focuses on technical inquiries and discussions regarding product specifications and operational parameter ranges, giving integrators a direct channel to verify torque, speed, and thermal data before deployment.
Conclusion
For engineers evaluating a robot joint actuator with a magnetic encoder, the technical specifications matter as much as the brand behind them. VAXOR-MOTOR’s combination of axial flux motor design, cycloidal gear reduction, and non-contact absolute magnetic encoding—paired with transparent technical documentation covering torque, speed, and thermal performance—positions the VAXOR module lineup as a detailed, specification-driven option for robotics, medical device, industrial automation, aerospace micro-drone, fluid transmission, and photonics applications seeking compact, precise actuation.
http://www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD. -
AuthorPosts

- You must be logged in to reply to this topic.